How OOMWOO cleaning algorithms work
Here are issues we've ran into building OOMWOO open-source vacuum's cleaning, mapping and navigation - and our solutions.
Here are issues we've ran into building OOMWOO open-source vacuum's cleaning, mapping and navigation - and our solutions.
A concise, copy-paste quickstart for running the OOMWOO robot vacuum entirely headless (no display) — aimed at LLM coding agents, CI, and automation. Every command below is verified against the makerspet/oomwoo:jazzy-dev Docker image (last re-verified 9 Aug 2026). No X…
This is the “hello world” of developing for OOMWOO. It’s deliberately simple — a reactive “drive forward, turn when blocked” coverage that, combined with SLAM, maps and roughly covers a room. Proper boustrophedon coverage is the clean-and-map RFC; this teaches…
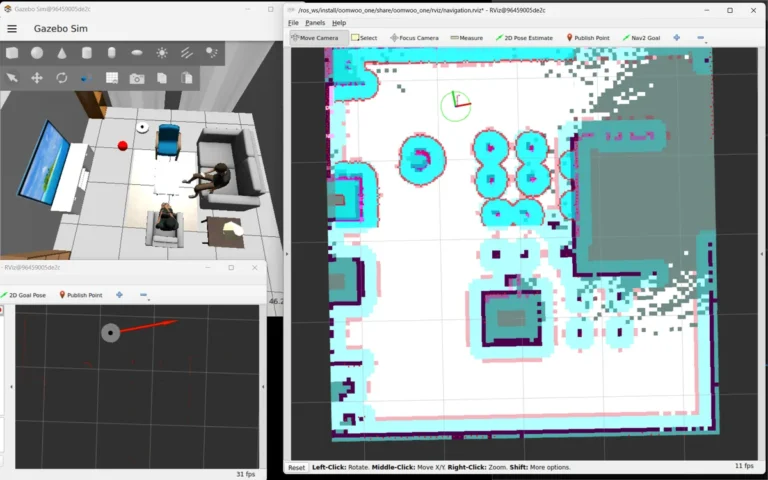
OOMWOO is an open-source robot vacuum you build yourself. oomwoo-one is the first model. This tutorial gets its ROS 2 simulation running in Gazebo so you can develop mapping, navigation, and cleaning behaviours with no hardware — everything runs in…
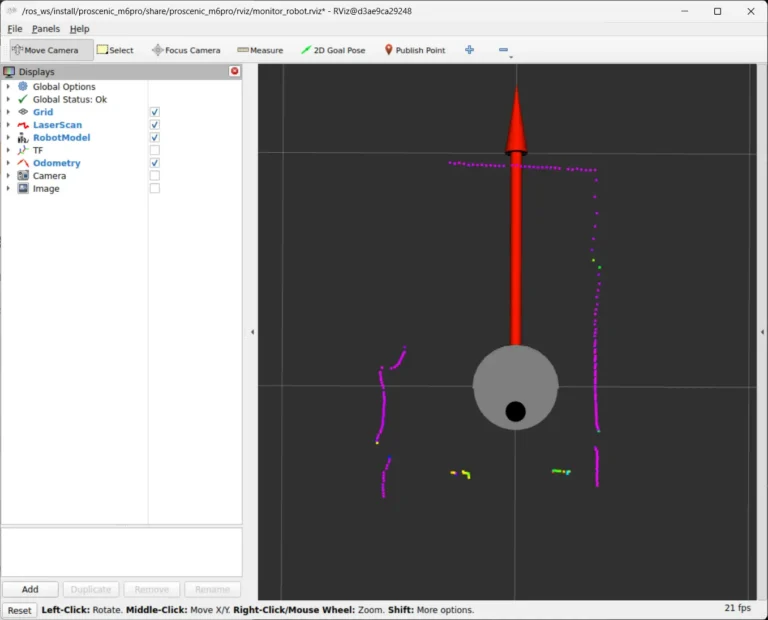
Tutorial Part 1 got SangamIO running on the vacuum, exposing its motors, wheel encoders, IMU and LiDAR over TCP port 5555. Part 2 connects that to ROS 2 the easy way — a prebuilt Docker image that already bundles everything:…
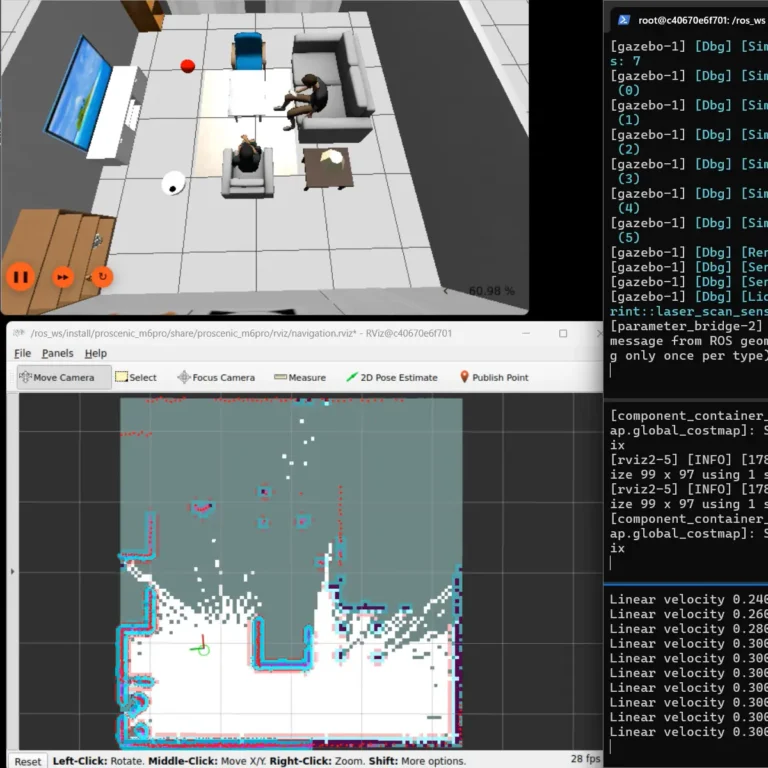
Run a full Proscenic M6 Pro vacuum simulation in Gazebo with the oomwoo ROS 2 image: SLAM mapping, autonomous Nav2 navigation, manual driving and bumper sensors — no hardware needed.
Turn a Proscenic M6 Pro robot vacuum into a ROS 2 robot: root it over ADB, flash the open-source SangamIO firmware, and bridge its LiDAR, odometry and motors into ROS 2 Jazzy as /scan, /odom and /cmd_vel.
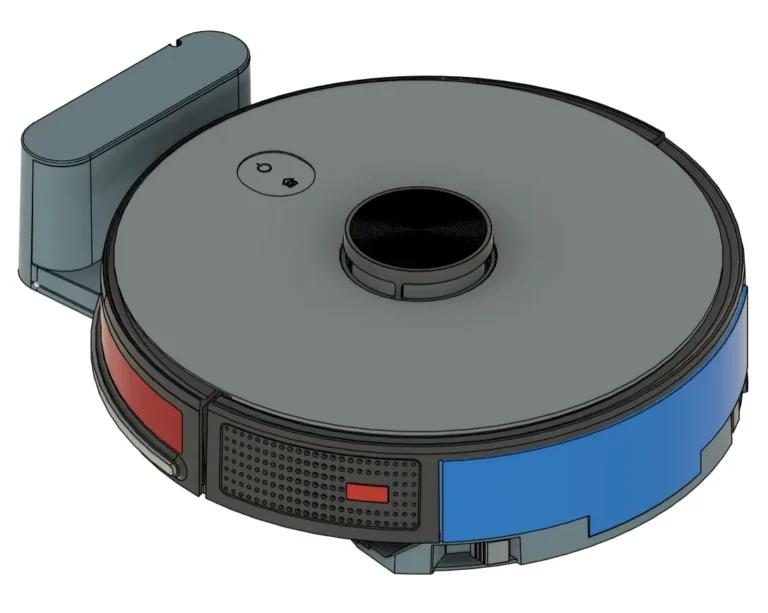
I’m starting a new build-in-public project: oomwoo, an open-source robot vacuum you build yourself. Raspberry Pi, ROS 2, 2D LiDAR, Home Assistant, 3D printed, local-first — and open from the first commit.
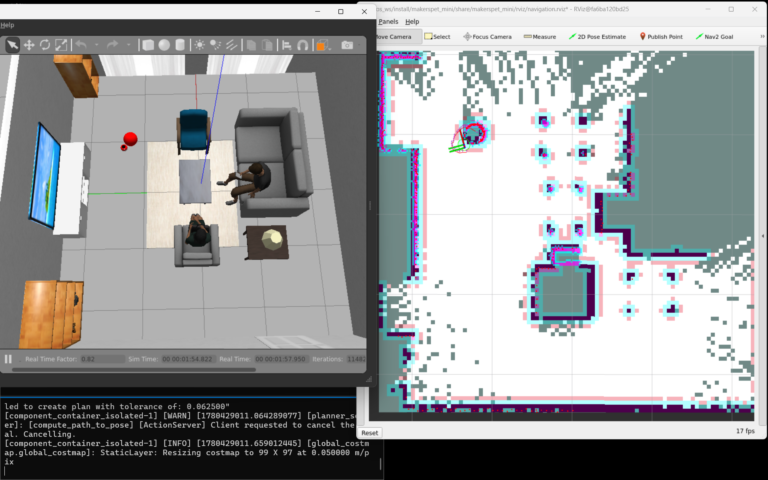
Are you learning ROS2 robotics but don’t have the hardware? No problem. Here is how you can do mapping and navigation in real-time simulations. Step 1 – Install Software Prerequisites The simulation works both on Windows and Ubuntu PCs. Windows…
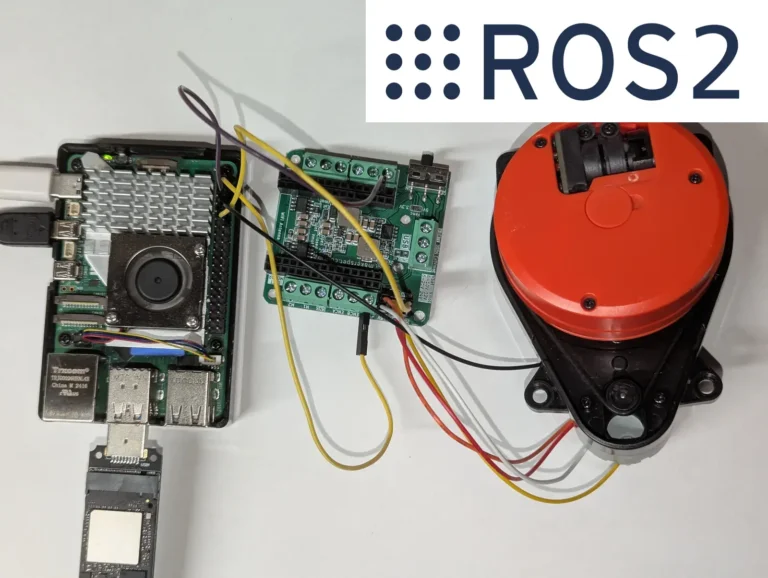
Publish the LDROBOT LD14P, Xiaomi LDS02RR, or 3irobotix Delta-2A to a ROS 2 /scan topic straight from a Raspberry Pi 5 — no microcontroller, and ROS 2 runs in a container. A C++ LaserScan driver built on kaiaai/LDS.
Questions about a kit, an order, or your build? Drop us a note — we usually reply within a day.