Free e-book: Build, Program a Self-Driving Robot
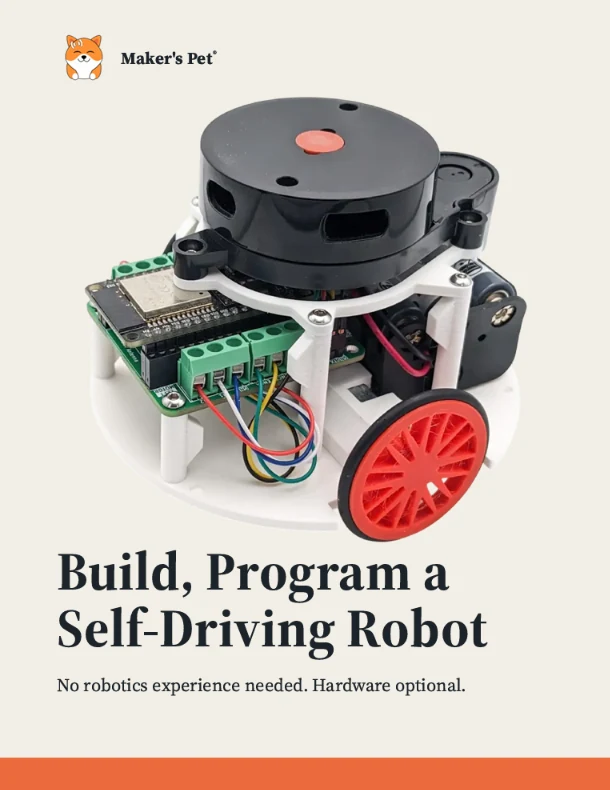
A free 209-page PDF that walks you through assembling, mapping and programming a LiDAR robot - with a simulation chapter so you can start without any hardware.
A free 209-page PDF that walks you through assembling, mapping and programming a LiDAR robot - with a simulation chapter so you can start without any hardware.
OOMWOO will be able to use an old Android phone instead of a Raspberry Pi CM4/CM5. Step one: ROS 2 in Termux - options, instructions and measured proot overhead on a Pixel 7.
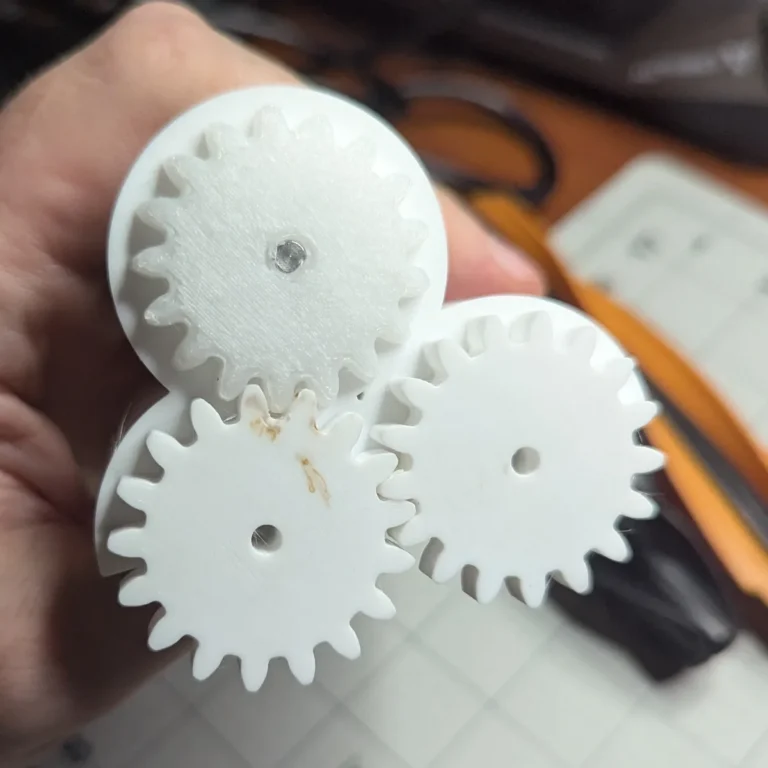
POM (Delrin) is the gear plastic in consumer robot vacuums, and notoriously hard to 3D print. Here is how I print it reliably: two sacrificial PETG layers first, then POM.
Future home for OOMWOO open-source vacuum cleaner robot build instructions. Bring-up notes for the sourced motors, fans and sensors – connectors, pinouts and measured currents – are in hardware bring-up, and the CAD pipeline behind these parts is in how…
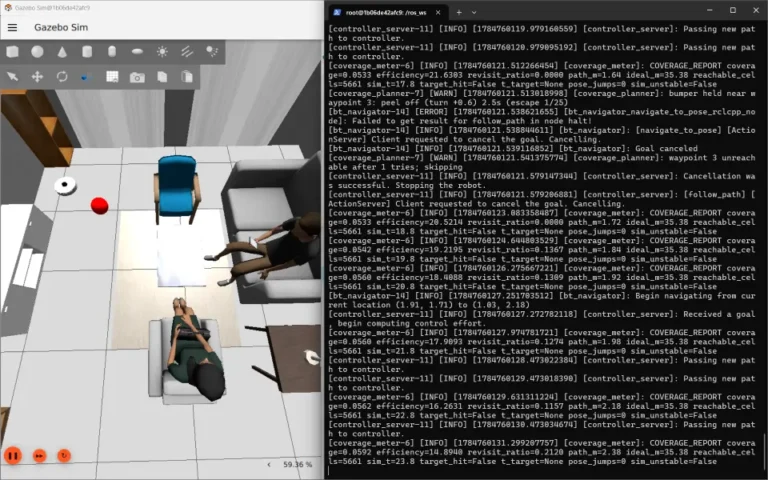
A concise, copy-paste quickstart for running the OOMWOO robot vacuum entirely headless (no display) — aimed at LLM coding agents, CI, and automation. Every command below is verified against the makerspet/oomwoo:jazzy-dev Docker image (last re-verified 9 Aug 2026). No X…
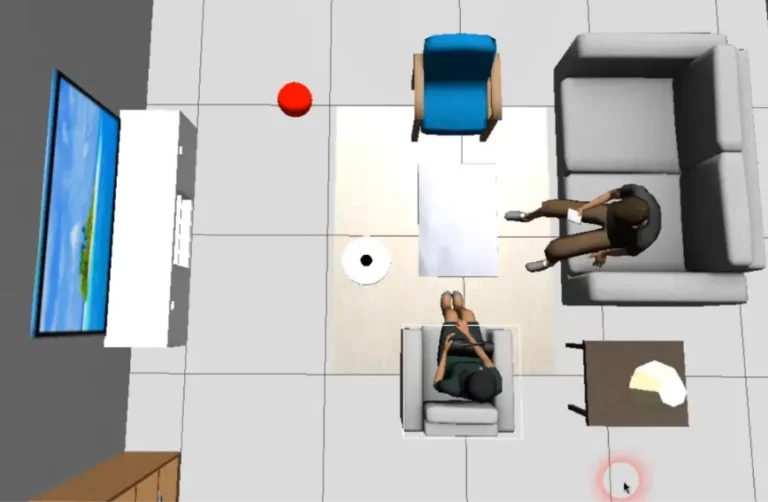
This is the “hello world” of developing for OOMWOO. It’s deliberately simple — a reactive “drive forward, turn when blocked” coverage that, combined with SLAM, maps and roughly covers a room. Proper boustrophedon coverage is the clean-and-map RFC; this teaches…
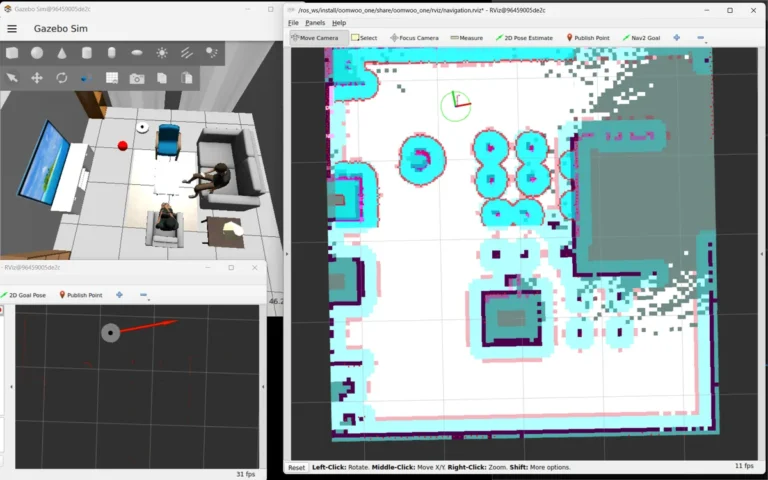
OOMWOO is an open-source robot vacuum you build yourself. oomwoo-one is the first model. This tutorial gets its ROS 2 simulation running in Gazebo so you can develop mapping, navigation, and cleaning behaviours with no hardware — everything runs in…
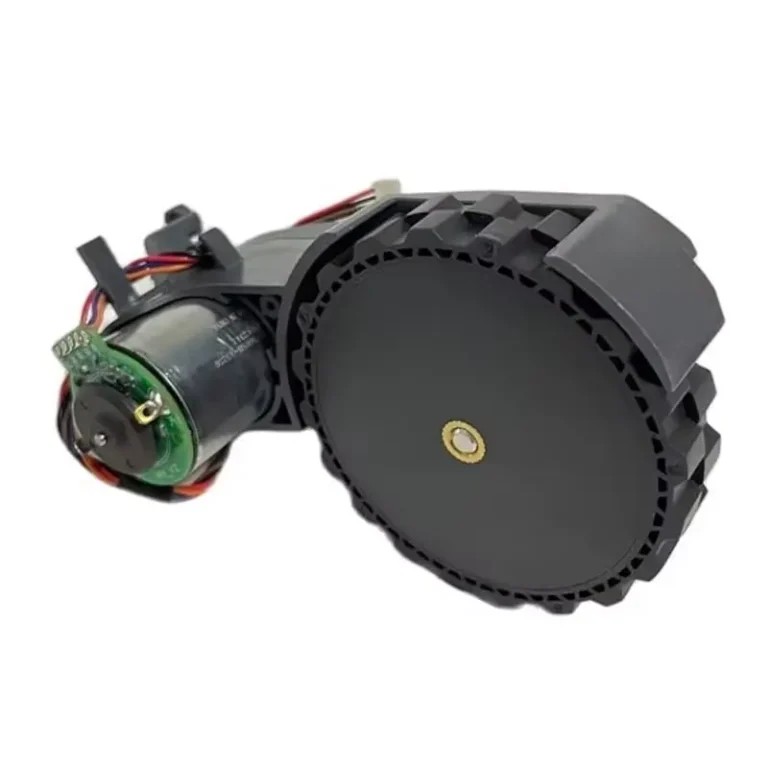
I started by drafting a list of parts and deciding which have to be sourced – and which should be 3D printed. I searched each part on AliExpress to see what is available abundantly – and at what price. Find…
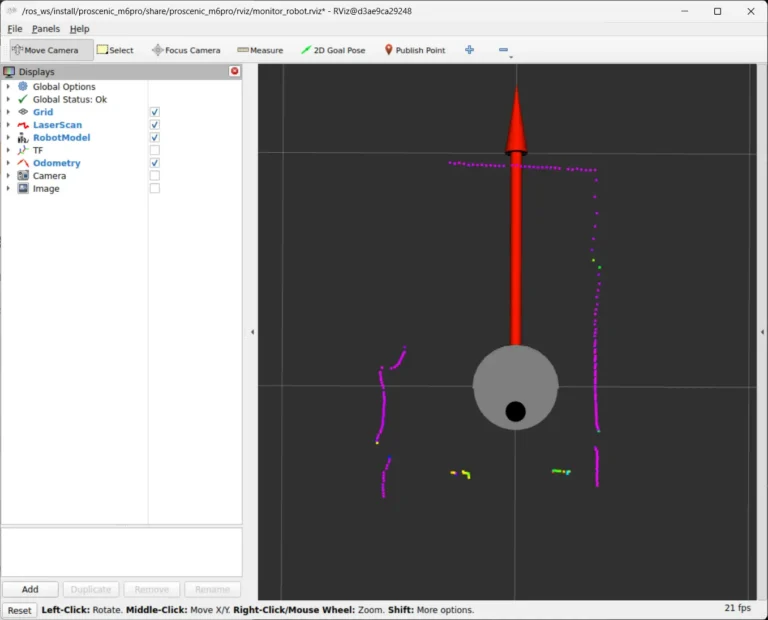
Tutorial Part 1 got SangamIO running on the vacuum, exposing its motors, wheel encoders, IMU and LiDAR over TCP port 5555. Part 2 connects that to ROS 2 the easy way — a prebuilt Docker image that already bundles everything:…
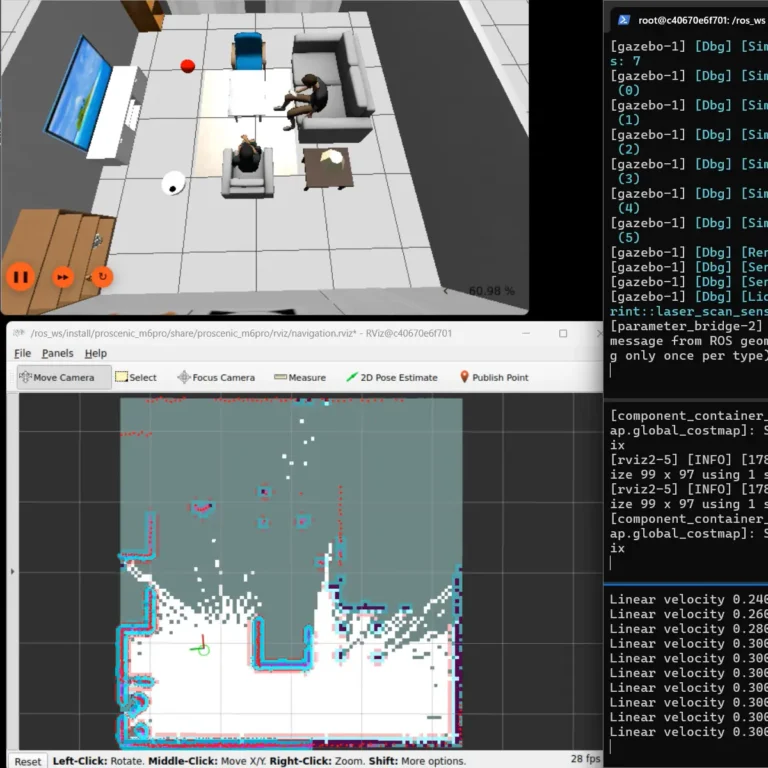
Run a full Proscenic M6 Pro vacuum simulation in Gazebo with the oomwoo ROS 2 image: SLAM mapping, autonomous Nav2 navigation, manual driving and bumper sensors — no hardware needed.
Questions about a kit, an order, or your build? Drop us a note — we usually reply within a day.