How OOMWOO cleaning algorithms work
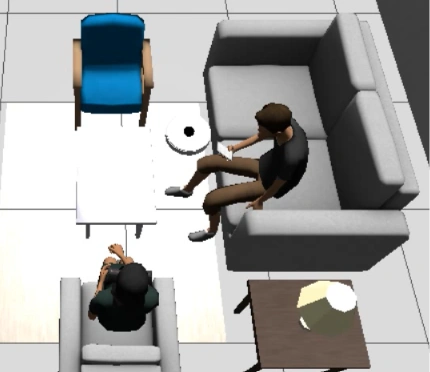
Here are issues we've ran into building OOMWOO open-source vacuum's cleaning, mapping and navigation - and our solutions.
Here are issues we've ran into building OOMWOO open-source vacuum's cleaning, mapping and navigation - and our solutions.
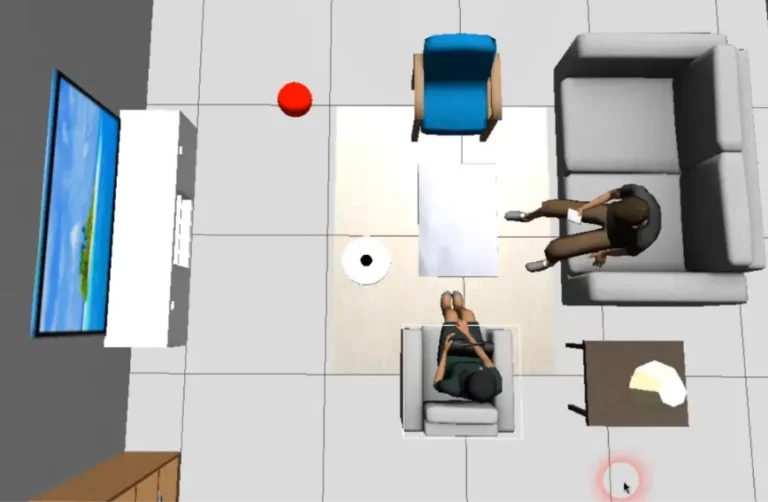
This is the “hello world” of developing for OOMWOO. It’s deliberately simple — a reactive “drive forward, turn when blocked” coverage that, combined with SLAM, maps and roughly covers a room. Proper boustrophedon coverage is the clean-and-map RFC; this teaches…
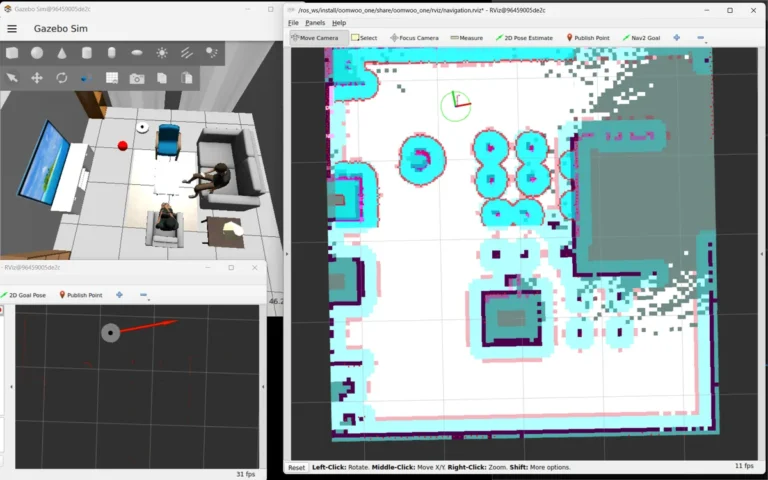
OOMWOO is an open-source robot vacuum you build yourself. oomwoo-one is the first model. This tutorial gets its ROS 2 simulation running in Gazebo so you can develop mapping, navigation, and cleaning behaviours with no hardware — everything runs in…
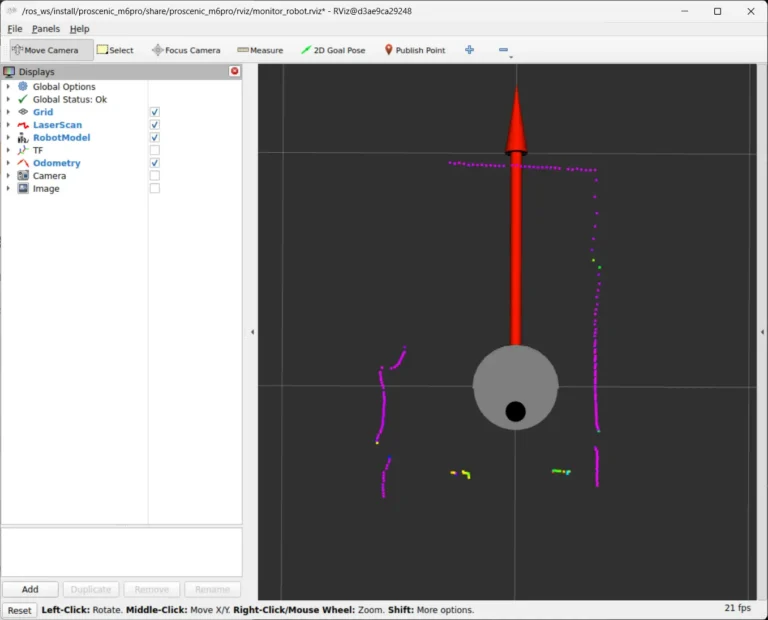
Tutorial Part 1 got SangamIO running on the vacuum, exposing its motors, wheel encoders, IMU and LiDAR over TCP port 5555. Part 2 connects that to ROS 2 the easy way — a prebuilt Docker image that already bundles everything:…
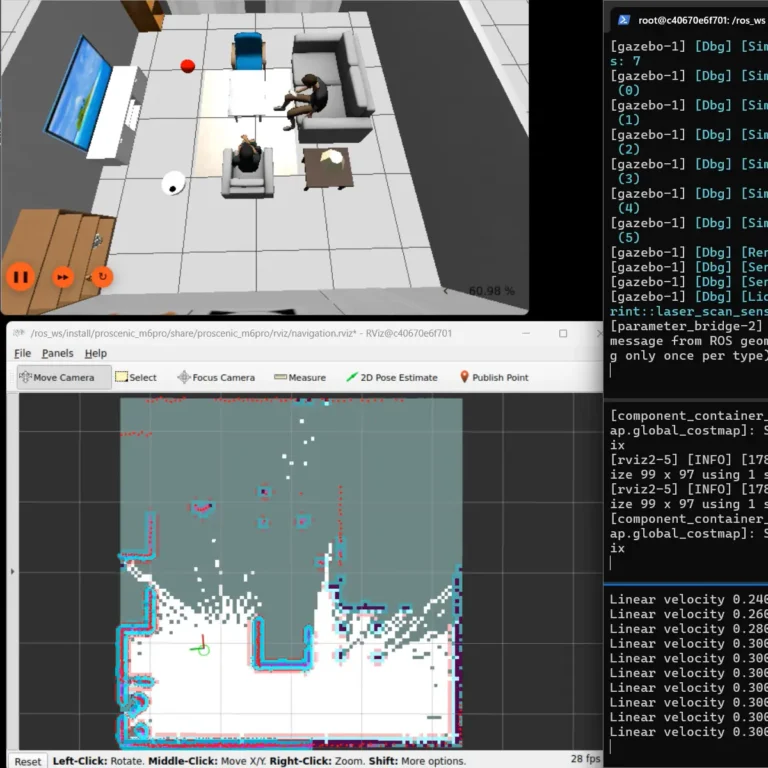
Run a full Proscenic M6 Pro vacuum simulation in Gazebo with the oomwoo ROS 2 image: SLAM mapping, autonomous Nav2 navigation, manual driving and bumper sensors — no hardware needed.
Turn a Proscenic M6 Pro robot vacuum into a ROS 2 robot: root it over ADB, flash the open-source SangamIO firmware, and bridge its LiDAR, odometry and motors into ROS 2 Jazzy as /scan, /odom and /cmd_vel.
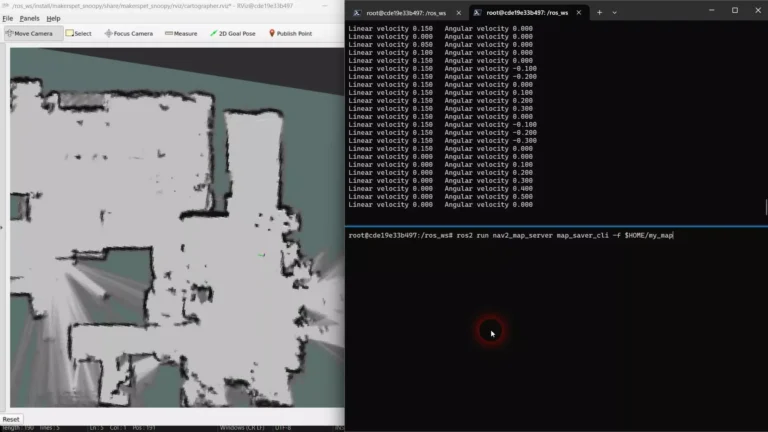
Watch Snoopy the pet robot map the house and navigate around the house using the newly-created map.This is a fraction of what your robot will be able to do. The full step-by-step tutorial is here. Snoopy maps the house Disclaimer…
Questions about a kit, an order, or your build? Drop us a note — we usually reply within a day.