OOMWOO PCBs – what we are building, how and why
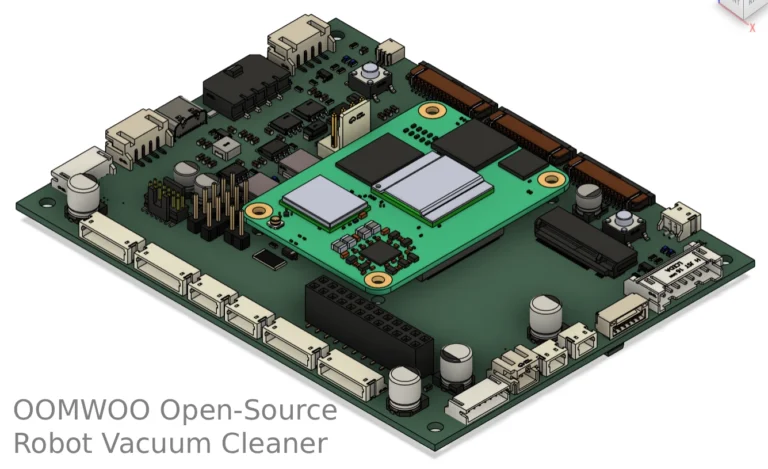
A module-by-module tour of the OOMWOO robot vacuum main board: compute, real-time control, power, fail-safe design, motors, sensors, audio and how we pick parts.
A module-by-module tour of the OOMWOO robot vacuum main board: compute, real-time control, power, fail-safe design, motors, sensors, audio and how we pick parts.
Here are issues we've ran into building OOMWOO open-source vacuum's cleaning, mapping and navigation - and our solutions.
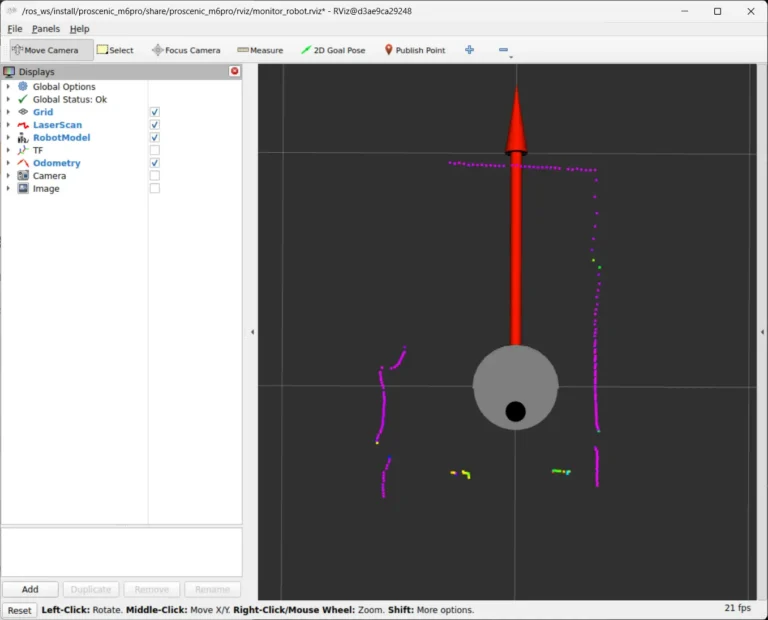
Tutorial Part 1 got SangamIO running on the vacuum, exposing its motors, wheel encoders, IMU and LiDAR over TCP port 5555. Part 2 connects that to ROS 2 the easy way — a prebuilt Docker image that already bundles everything:…
Turn a Proscenic M6 Pro robot vacuum into a ROS 2 robot: root it over ADB, flash the open-source SangamIO firmware, and bridge its LiDAR, odometry and motors into ROS 2 Jazzy as /scan, /odom and /cmd_vel.
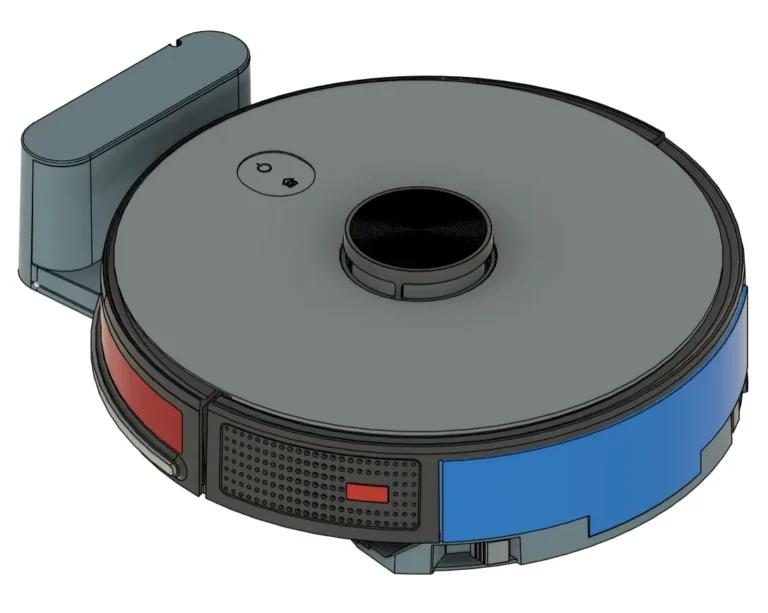
I’m starting a new build-in-public project: oomwoo, an open-source robot vacuum you build yourself. Raspberry Pi, ROS 2, 2D LiDAR, Home Assistant, 3D printed, local-first — and open from the first commit.
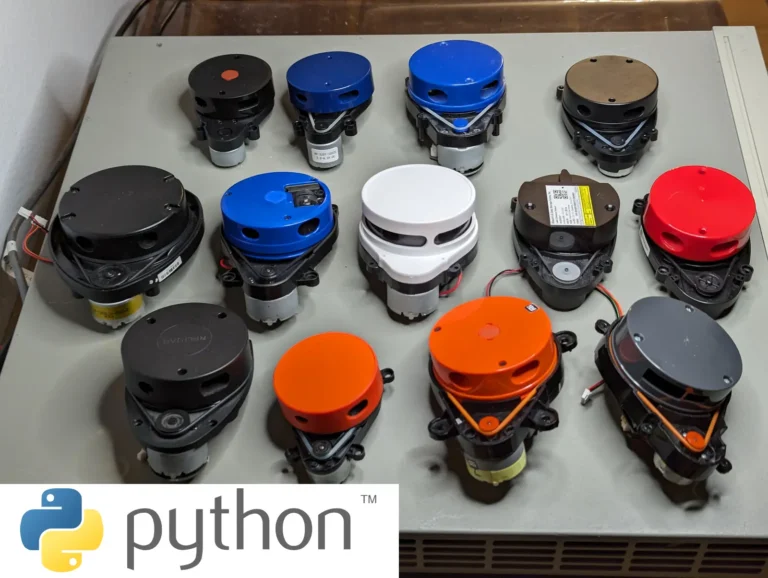
lds2d is a pure-Python driver for 2D LiDARs on Linux including the Raspberry Pi — a Pythonic port of the kaiaai/LDS C++ library. lds2d supports 23+ LiDAR models today: Try it in 60 seconds – without any hardware Once lds2d…
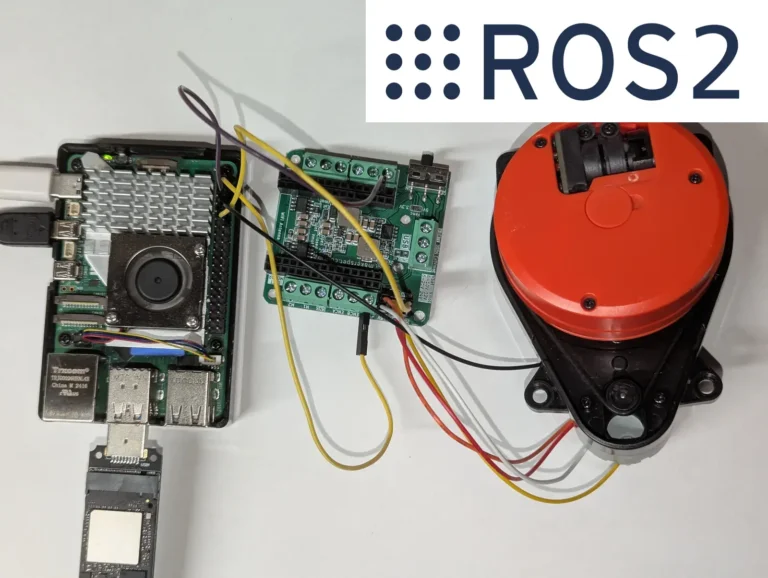
Publish the LDROBOT LD14P, Xiaomi LDS02RR, or 3irobotix Delta-2A to a ROS 2 /scan topic straight from a Raspberry Pi 5 — no microcontroller, and ROS 2 runs in a container. A C++ LaserScan driver built on kaiaai/LDS.
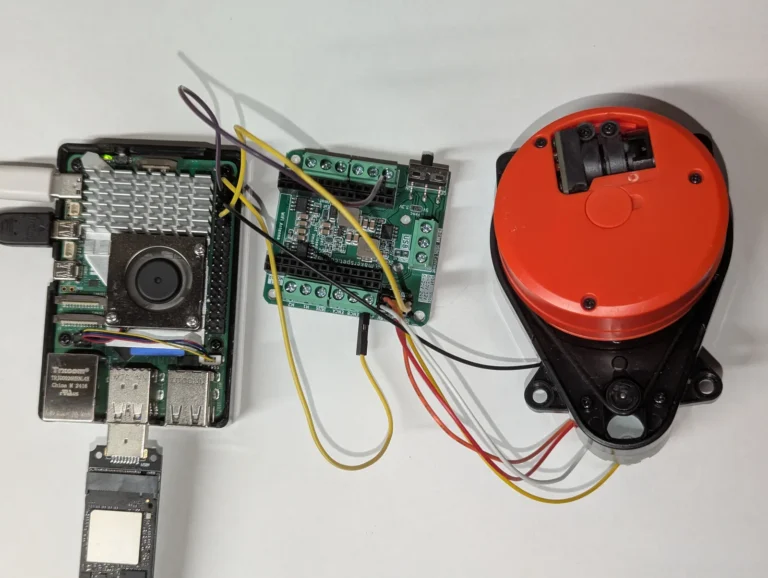
Read distance data from a 3irobotix Delta-2A on a Raspberry Pi in Python — and run the PID + PWM loop that spins its motor at 6 Hz via the Maker's Pet driver board, no ESP32 required.
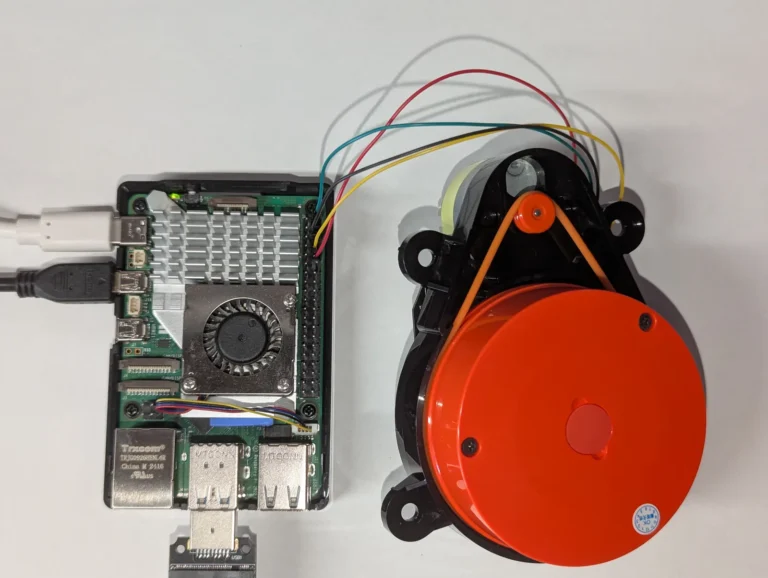
Read distance data from the ~$15 Xiaomi LDS02RR on a Raspberry Pi in Python — and run the PID + PWM loop that spins its motor at 5 Hz, which the LDS02RR cannot do for itself.
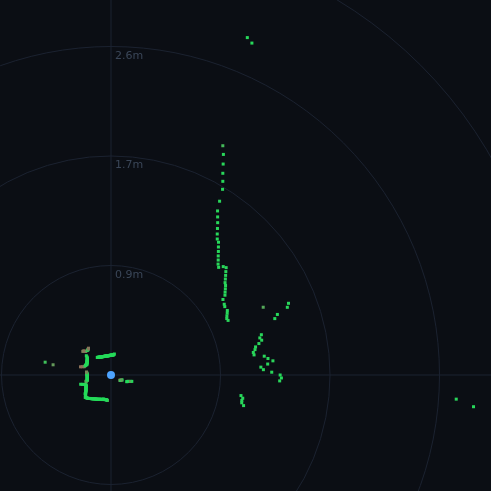
Turn the LD14P's raw distance data into a live polar radar you watch in any web browser — served straight from a headless Raspberry Pi with Flask. Part 3 of the LD14P + Raspberry Pi series.
Questions about a kit, an order, or your build? Drop us a note — we usually reply within a day.